Heavy-load mobile automation
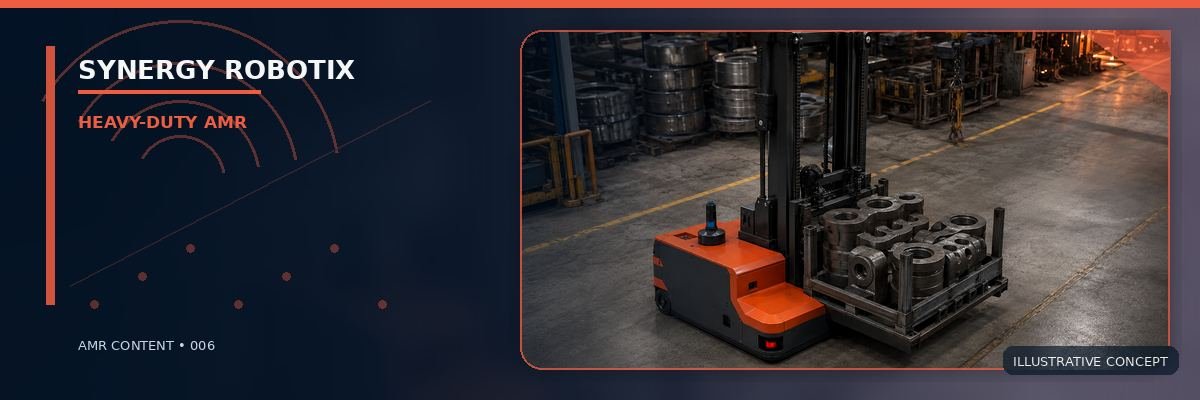
Heavy-Duty Automated Mobile Robots for Industrial Loads
Engineer autonomous load handling around the carrier, centre of gravity, route, transfer geometry, traffic conditions and approved operating envelope.
Match Heavy-Duty Automated Mobile Robots for Industrial Loads to the real load and route
Heavy-Duty Automated Mobile Robots for Industrial Loads is best assessed as part of the wider material-flow or mission system. Navigation, handling, communications, energy, maintenance and operator intervention need to support the same operating concept.
For Heavy-Duty Automated Mobile Robots for Industrial Loads, operations, engineering, safety, controls or IT, maintenance and procurement should use one shared requirement set so technical and commercial decisions remain aligned.
Load acquisition
Define load dimensions, mass, centre of gravity, carrier condition, orientation and transfer method and the tolerance at pickup. Reliable travel cannot compensate for an unstable or incorrectly presented load. Include this subject in the staging review for Heavy-Duty Automated Mobile Robots for Industrial Loads.
Route and manoeuvring
Measure aisle width, turning sweep, floor condition, gradients, crossings and waiting positions with the intended carrier and load represented. Include this subject in the staging review for Heavy-Duty Automated Mobile Robots for Industrial Loads.
Delivery and release
Confirm destination geometry, placement tolerance, load release, completion signal and recovery when a location is occupied or outside tolerance. Use approved data for Heavy-Duty Automated Mobile Robots for Industrial Loads before making a performance commitment.
Engineering inputs that shape Heavy-Duty Automated Mobile Robots for Industrial Loads
Build the requirement for heavy-Duty Automated Mobile Robots for Industrial Loads from representative operating data. Capture origins, destinations, loaded and empty travel, task frequency, peak demand, waiting, priority work, charging opportunities and the manual fallback. Average demand alone can hide the short periods that determine vehicle count or service level.
Survey manufacturing and industrial facilities using the intended load or payload. Record load dimensions, mass, centre of gravity, carrier condition, orientation and transfer method, route width, turns, surfaces, gradients, crossings, doors, lifts, transfer geometry, lighting, contamination and wireless coverage. Measurements should include the least forgiving parts of the process, not only the easiest demonstration route. Record the agreed treatment for Heavy-Duty Automated Mobile Robots for Industrial Loads in the application specification.
Evidence to prepare before equipment selection
- Origins, destinations and task demand by period
- Representative load, carrier or payload evidence
- Measured route and transfer-point geometry
- Traffic, people and shared-resource conditions
- System interfaces and ownership
- Normal, peak, exception and recovery criteria
How Heavy-Duty Automated Mobile Robots for Industrial Loads moves from request to completion
For Heavy-Duty Automated Mobile Robots for Industrial Loads, the operating sequence should make task ownership, physical handling, system states and recovery visible from release through completion.
Release the handling task
The control system confirms load identity, source, destination, priority and location readiness. Review this decision for Heavy-Duty Automated Mobile Robots for Industrial Loads whenever the workflow or site changes.
Align and acquire
The vehicle approaches using the approved handling interface and verifies load dimensions, mass, centre of gravity, carrier condition, orientation and transfer method before taking the load. Include this subject in the staging review for Heavy-Duty Automated Mobile Robots for Industrial Loads.
Move in the safe travel state
Route planning, traffic controls and protective functions manage the loaded journey and shared resources. Test this element of Heavy-Duty Automated Mobile Robots for Industrial Loads under representative site conditions.
Position and transfer
The system confirms destination geometry, access and placement conditions before releasing the load. Confirm this point for Heavy-Duty Automated Mobile Robots for Industrial Loads with representative operating evidence.
Close or recover the task
Successful delivery updates the controlling system; incomplete pickup, blocked access or unstable presentation follows an agreed exception path. Include this subject in the staging review for Heavy-Duty Automated Mobile Robots for Industrial Loads.
Connect Heavy-Duty Automated Mobile Robots for Industrial Loads to equipment and information flow
Interfaces around Heavy-Duty Automated Mobile Robots for Industrial Loads should be stateful, testable and owned. A clear handshake is easier to operate and support than a collection of one-way commands.
Warehouse or production tasks
Use WMS, WCS, MES, ERP or operator requests to release Heavy-Duty Automated Mobile Robots for Industrial Loads missions with source, destination, load and priority. Include this subject in the staging review for Heavy-Duty Automated Mobile Robots for Industrial Loads.
Location and load identity
Confirm pallet or carrier identity, rack or floor location, occupancy and the correct handling direction before pickup or putaway. Review this decision for Heavy-Duty Automated Mobile Robots for Industrial Loads whenever the workflow or site changes.
Protected transfer logic
Coordinate doors, rack aisles, machines, transfer stations and exclusion zones through explicit readiness and completion states. Test this element of Heavy-Duty Automated Mobile Robots for Industrial Loads under representative site conditions.
Operational visibility
Show task, vehicle, load, mast or handling state, battery, alarms and recovery actions to the teams responsible for the process. Record the agreed treatment for Heavy-Duty Automated Mobile Robots for Industrial Loads in the application specification.
Design safe operation and practical recovery for Heavy-Duty Automated Mobile Robots for Industrial Loads
Safety for Heavy-Duty Automated Mobile Robots for Industrial Loads should be designed around the complete operating environment. Consider people, manual vehicles, blind corners, crossings, doors, transfer zones, unstable or damaged loads, maintenance access and foreseeable recovery actions.
Vehicle sensing is only one layer. Speed and route rules, layout, separation, visibility, workstation design, access management, training, procedures and emergency arrangements may also be required. Competent project stakeholders must select and validate the measures for the installed application. Review this decision for Heavy-Duty Automated Mobile Robots for Industrial Loads whenever the workflow or site changes.
Subjects to include in the installed review
- Operating modes and authorised users
- Shared-space traffic and crossings
- Load and transfer-point hazards
- Protective functions and site controls
- Maintenance and manual recovery
- Emergency stop and controlled restart
Evidence to review before approving Heavy-Duty Automated Mobile Robots for Industrial Loads
For Heavy-Duty Automated Mobile Robots for Industrial Loads, convert assumptions into records that can be reviewed, tested and maintained through the project lifecycle.
| Decision area | Evidence to prepare | How to validate it |
|---|---|---|
| Workflow | Origins, destinations, demand, queues, priority and fallback | Run normal and peak mission patterns |
| Load or payload | Load dimensions, mass, centre of gravity, carrier condition, orientation and transfer method | Use representative carriers and worst credible conditions |
| Route and environment | Manufacturing and industrial facilities, including constraints and shared traffic | Test the least-forgiving sections |
| Interfaces | Wms, wcs, erp or mes tasks, scanners, conveyors, doors, lifts, call stations, production controls and charging points | Challenge acknowledgement, timeout and recovery |
| Operations | Charging, maintenance, training, support and change control | Rehearse intervention and controlled restart |
Measure the operating outcome for Heavy-Duty Automated Mobile Robots for Industrial Loads
For Heavy-Duty Automated Mobile Robots for Industrial Loads, useful performance measures connect mobile activity with the workflow result and the effort needed to sustain it.
Flow reliability
Track whether Heavy-Duty Automated Mobile Robots for Industrial Loads completes the intended missions with stable handoffs, visible queues and controlled exception handling. Include this subject in the staging review for Heavy-Duty Automated Mobile Robots for Industrial Loads.
Operational effort
For Heavy-Duty Automated Mobile Robots for Industrial Loads, measure walking, driving, waiting, manual intervention, supervision and recovery work before and after implementation. Review this decision for Heavy-Duty Automated Mobile Robots for Industrial Loads whenever the workflow or site changes.
System availability
Review completed tasks, downtime causes, charger or resource queues, maintenance and return-to-service time for Heavy-Duty Automated Mobile Robots for Industrial Loads. Confirm this point for Heavy-Duty Automated Mobile Robots for Industrial Loads with representative operating evidence.
A staged route from concept to acceptance for Heavy-Duty Automated Mobile Robots for Industrial Loads
A controlled Heavy-Duty Automated Mobile Robots for Industrial Loads project should move through decision gates rather than treating installation as one event. Each stage should confirm that assumptions about the task, load or payload, site, interfaces, safety responsibilities and operating model still match the evidence.
Acceptance should use representative loads, routes, traffic and interfaces. Include blocked paths, unavailable destinations, failed handshakes, low energy, emergency stops, manual recovery and controlled restart, then hand over clear roles and maintenance routines. Include this subject in the staging review for Heavy-Duty Automated Mobile Robots for Industrial Loads.
Discover
Map the workflow or mission, stakeholders, current constraints and measurable outcome. Review this decision for Heavy-Duty Automated Mobile Robots for Industrial Loads whenever the workflow or site changes.
Survey
Capture representative loads or payloads, route or terrain, transfer points, services, traffic and hazards. Confirm this point for Heavy-Duty Automated Mobile Robots for Industrial Loads with representative operating evidence.
Engineer
Select the architecture, define interfaces, controls, safety measures, energy and support responsibilities. Review this decision for Heavy-Duty Automated Mobile Robots for Industrial Loads whenever the workflow or site changes.
Implement
Configure, integrate and test components with controlled change and traceable issue resolution. Review this decision for Heavy-Duty Automated Mobile Robots for Industrial Loads whenever the workflow or site changes.
Accept
Run representative normal, peak, fault and recovery tests before training and operational handover. Review this decision for Heavy-Duty Automated Mobile Robots for Industrial Loads whenever the workflow or site changes.
Related resources for Heavy-Duty Automated Mobile Robots for Industrial Loads
Use these Synergy Robotix resources to compare adjacent product, application, integration and selection decisions connected with Heavy-Duty Automated Mobile Robots for Industrial Loads.
Heavy-Duty Automated Mobile Robots for Industrial Loads: frequently asked questions
What information is needed to assess Heavy-Duty Automated Mobile Robots for Industrial Loads?
Prepare the workflow or mission, task demand, route or operating area, load dimensions, mass, centre of gravity, carrier condition, orientation and transfer method, transfer method, interfaces, operating hours, traffic and known hazards. Include this subject in the staging review for Heavy-Duty Automated Mobile Robots for Industrial Loads.
How is the number or size of mobile robots determined?
Use loaded and empty travel, pickup and delivery time, waiting, charging, congestion, availability and the required service level. Peak demand and exceptions matter as well as averages. Record the agreed treatment for Heavy-Duty Automated Mobile Robots for Industrial Loads in the application specification.
Can mobile robots operate around people and manual vehicles?
Mixed operation may be possible when the installed risk assessment, protective functions, layout, traffic rules, training and emergency arrangements support it. Use approved data for Heavy-Duty Automated Mobile Robots for Industrial Loads before making a performance commitment.
How does the system connect to warehouse or production controls?
Interfaces may exchange task, load, source, destination, priority, readiness and completion states through WMS, WCS, ERP or MES tasks, scanners, conveyors, doors, lifts, call stations, production controls and charging points. Define timeouts, alarms and recovery ownership. Use approved data for Heavy-Duty Automated Mobile Robots for Industrial Loads before making a performance commitment.
What should be validated before handover?
Test representative missions, loads, routes, traffic, transfers, charging and interfaces, including blocked paths, failed signals, low energy, emergency stops and controlled restart. Use approved data for Heavy-Duty Automated Mobile Robots for Industrial Loads before making a performance commitment.
Plan Heavy-Duty Automated Mobile Robots for Industrial Loads around the real operation
Share the load or payload, route or operating domain, task demand, transfer points, interfaces and known constraints for Heavy-Duty Automated Mobile Robots for Industrial Loads. Synergy Robotix can use those inputs to shape an application-specific engineering discussion.